Linux API/v4l2022. 7. 13. 19:47

v4l2 디버깅을 위해서는 아래와 같이 설정해주면 dmesg에 출력되게 된다.

# echo 0x1f > /sys/class/video4linux/video1/dev_debug

[링크 : https://stackoverflow.com/questions/24330671/v4l2-kernel-space-debugging]


guvcview 유틸리티를 이용해서 테스트.

하단의 exposure, auto / (absolute) / Auto Priority 관련 설정을 바꿀때 나오는 값 확인


Exposure, Auto - Aperture Priority Mode

[ 1041.346246] video2: VIDIOC_DQEVENT: type=0x3, pending=0, sequence=13, id=10094850, timestamp=1040.623934215
[ 1041.346259] changes=0x3, type=1, value=3216, flags=0x10, minimum=39, maximum=10000, step=1, default_value=156
[ 1041.346272] video2: VIDIOC_DQEVENT: error -2: type=0x0, pending=0, sequence=0, id=0, timestamp=0.000000000


Exposure, Auto - Manual / 3216

[ 1128.312839] video2: VIDIOC_S_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0901/0x3
[ 1128.312866] video2: VIDIOC_G_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0901/0x3


Exposure (Absolute)

[  621.732496] video2: VIDIOC_S_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xe55
[  621.733321] video2: VIDIOC_G_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xe55
[  621.749803] video2: VIDIOC_S_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xe56
[  621.750586] video2: VIDIOC_G_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xe56
[  621.784790] video2: VIDIOC_S_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xcbf
[  621.785731] video2: VIDIOC_G_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xcbf
[  621.802333] video2: VIDIOC_S_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xcc0
[  621.803150] video2: VIDIOC_G_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xcc0
[  621.833353] video2: VIDIOC_S_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xc90
[  621.834204] video2: VIDIOC_G_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xc90
[  621.849972] video2: VIDIOC_S_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xc90
[  621.850772] video2: VIDIOC_G_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0902/0xc90


Exposure, Auto Priority (선택)

[ 1464.855961] video2: VIDIOC_S_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0903/0x1
[ 1464.855989] video2: VIDIOC_G_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0903/0x1


Exposure, Auto Priority (미선택)

[ 1519.669796] video2: VIDIOC_S_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0903/0x0
[ 1519.669856] video2: VIDIOC_G_EXT_CTRLS: which=0x9a0000, count=1, error_idx=0, request_fd=0, id/val=0x9a0903/0x0


'Linux API > v4l' 카테고리의 다른 글

v4l2-ctl 밝기 조절  (0) 2022.07.06
v4l2 timestamp  (0) 2017.04.19
uv4l  (0) 2015.09.13
리눅스에 웹캠 연결시 인식  (5) 2009.12.06
Posted by 구차니
Linux API/v4l2022. 7. 6. 15:21


$ v4l2-ctl

General/Common options:
  --all              display all information available
  -C, --get-ctrl=<ctrl>[,<ctrl>...]
                     get the value of the controls [VIDIOC_G_EXT_CTRLS]
  -c, --set-ctrl=<ctrl>=<val>[,<ctrl>=<val>...]
                     set the value of the controls [VIDIOC_S_EXT_CTRLS]
  -D, --info         show driver info [VIDIOC_QUERYCAP]
  -d, --device=<dev> use device <dev> instead of /dev/video0
                     if <dev> starts with a digit, then /dev/video<dev> is used
  -e, --out-device=<dev> use device <dev> for output streams instead of the
                     default device as set with --device
                     if <dev> starts with a digit, then /dev/video<dev> is used
  -h, --help         display this help message
  --help-all         all options
  --help-io          input/output options
  --help-misc        miscellaneous options
  --help-overlay     overlay format options
  --help-sdr         SDR format options
  --help-selection   crop/selection options
  --help-stds        standards and other video timings options
  --help-streaming   streaming options
  --help-tuner       tuner/modulator options
  --help-vbi         VBI format options
  --help-vidcap      video capture format options
  --help-vidout      vidout output format options
  --help-edid        edid handling options
  -k, --concise      be more concise if possible.
  -l, --list-ctrls   display all controls and their values [VIDIOC_QUERYCTRL]
  -L, --list-ctrls-menus
                     display all controls and their menus [VIDIOC_QUERYMENU]
  -r, --subset=<ctrl>[,<offset>,<size>]+
                     the subset of the N-dimensional array to get/set for control <ctrl>,
                     for every dimension an (<offset>, <size>) tuple is given.
  -w, --wrapper      use the libv4l2 wrapper library.
  --list-devices     list all v4l devices
  --log-status       log the board status in the kernel log [VIDIOC_LOG_STATUS]
  --get-priority     query the current access priority [VIDIOC_G_PRIORITY]
  --set-priority=<prio>
                     set the new access priority [VIDIOC_S_PRIORITY]
                     <prio> is 1 (background), 2 (interactive) or 3 (record)
  --silent           only set the result code, do not print any messages
  --sleep=<secs>     sleep <secs>, call QUERYCAP and close the file handle
  --verbose          turn on verbose ioctl status reporting


$ v4l2-ctl -l -d /dev/video2
                     brightness 0x00980900 (int)    : min=-64 max=64 step=1 default=0 value=0
                       contrast 0x00980901 (int)    : min=0 max=95 step=1 default=5 value=5
                     saturation 0x00980902 (int)    : min=0 max=100 step=1 default=60 value=60
                            hue 0x00980903 (int)    : min=-2000 max=2000 step=1 default=0 value=0
 white_balance_temperature_auto 0x0098090c (bool)   : default=1 value=1
                          gamma 0x00980910 (int)    : min=100 max=300 step=1 default=100 value=100
                           gain 0x00980913 (int)    : min=1 max=8 step=1 default=1 value=1
           power_line_frequency 0x00980918 (menu)   : min=0 max=2 default=1 value=2
      white_balance_temperature 0x0098091a (int)    : min=2800 max=6500 step=1 default=4600 value=4600 flags=inactive
                      sharpness 0x0098091b (int)    : min=1 max=7 step=1 default=2 value=2
         backlight_compensation 0x0098091c (int)    : min=0 max=1 step=1 default=1 value=1
                  exposure_auto 0x009a0901 (menu)   : min=0 max=3 default=3 value=1
              exposure_absolute 0x009a0902 (int)    : min=10 max=626 step=1 default=156 value=25


v4l2-ctl -d /dev/video2 -c exposure_absolute=70
v4l2-ctl -d /dev/video2 -c exposure_absolute=600

[링크 : https://thirdnsov.tistory.com/107]

'Linux API > v4l' 카테고리의 다른 글

v4l2 debug  (0) 2022.07.13
v4l2 timestamp  (0) 2017.04.19
uv4l  (0) 2015.09.13
리눅스에 웹캠 연결시 인식  (5) 2009.12.06
Posted by 구차니
Linux API/joystick2022. 6. 15. 13:19

예전에 리눅스를 통해 어떻게 쓰나 찾을때는 안나왔던것 같은데 이제 발견


% fftest /dev/input/eventXX

[링크 : https://www.kernel.org/doc/html/latest/input/ff.html]


해당 유틸리티 실행하려니 joystick이라는 패키지를 설치하라고 한다.

$ fftest

Command 'fftest' not found, but can be installed with:

sudo apt install joystick

'Linux API > joystick' 카테고리의 다른 글

linux/joystick.h 파일  (0) 2012.02.05
리눅스에서 조이스틱 값 읽어오기  (0) 2012.02.04
Posted by 구차니
Linux API/network2022. 6. 9. 11:17

etherCAT 이라는 사악한(?) 프로토콜 때문에 해당 장비 개발자에게 주워들은 이야기


AF_PACKET 이라는걸로 열면 link layer로 열려서 통신이 가능해서

etherCAT 이라고 특별한 드라이버를 설치하는건 아니라고 한다.


AF_INET 를 주로 사용했지 다른걸 찾아볼 생각을 안했구나..

Name Purpose Man page
AF_UNIX, AF_LOCAL Local communication unix(7)
AF_INET IPv4 Internet protocols ip(7)
AF_INET6 IPv6 Internet protocols ipv6(7)
AF_IPX IPX - Novell protocols
AF_NETLINK Kernel user interface device netlink(7)
AF_X25 ITU-T X.25 / ISO-8208 protocol x25(7)
AF_AX25 Amateur radio AX.25 protocol
AF_ATMPVC Access to raw ATM PVCs
AF_APPLETALK Appletalk ddp(7)
AF_PACKET Low level packet interface packet(7)

[링크 : https://linux.die.net/man/2/socket]

[링크 : https://iplab.naist.jp/class/2018/materials/hands-on/layer-2-raw-socket/]

'Linux API > network' 카테고리의 다른 글

bind(): Address already in use  (0) 2023.07.21
recv 와 read 차이  (0) 2023.06.23
linux tcp server listen accept connect  (0) 2022.05.11
ssl socket 예제  (0) 2022.03.25
TCP timeout  (0) 2020.09.29
Posted by 구차니
Linux API/network2022. 5. 11. 15:20

서버 사이드 listen + accept

클라이언트 사이드 connect

[링크 : https://charsyam.wordpress.com/2018/01/09/입-개발-ipv4-tcp-socket-listen-에서-accept-까지/]


[링크 : https://www.ibm.com/docs/en/i/7.2?topic=designs-example-nonblocking-io-select]

[링크 : https://velog.io/@jyongk/TCP-Socket-Blocking-Non-Blocking]

[링크 : https://ospace.tistory.com/189]


accept poll 처리

accept 시에 돌려받는 fd로 io를 처리하면 accept 역시 poll로 처리가 가능해진다.

listen 포트는 그대로 둔채, accept 하고 나서 다른 포트로 통신하게 되는 이유가 이거였나..

[링크 : https://www.crocus.co.kr/544]

[링크 : https://www.joinc.co.kr/w/Site/Network_Programing/Documents/Poll]

'Linux API > network' 카테고리의 다른 글

recv 와 read 차이  (0) 2023.06.23
AF_PACKET로 link layer 열기  (0) 2022.06.09
ssl socket 예제  (0) 2022.03.25
TCP timeout  (0) 2020.09.29
UDS (Unix Domain Socket)  (0) 2020.09.01
Posted by 구차니
Linux API/network2022. 3. 25. 14:12

복붙하면 "와 ' 가 문제가 생기고

우분투 18.04 에서 빌드하면 client 쪽의 소스에서

SSLv3_client_method() 함수가 없다고 나오니, SSLv23_client_method 으로 바꾸어 주어야 한다.

[링크 : http://pchero21.com/?p=603]


실행하면 보안인증서 경로 문제로 실행이 안되는데 인증서는 어떻게 생성해야 하려나..

[링크 : https://m.blog.naver.com/espeniel/221845133507]


+ 빌드

$ sudo apt-get install libssl-dev

[링크 : https://stackoverflow.com/questions/43131708/fatal-error-openssl-rsa-h-no-such-file-or-directory]


-lssl 옵션을 주고 빌드하는데 아래와 같은 에러 발생시에는

/usr/bin/ld: /tmp/ccHIcKux.o: undefined reference to symbol 'ERR_print_errors_fp@@OPENSSL_1_1_0'
//usr/lib/x86_64-linux-gnu/libcrypto.so.1.1: error adding symbols: DSO missing from command line
collect2: error: ld returned 1 exit status


-lcrytpo 까지 추가해주면 해결!

% gcc -o test test.c -L/usr/lib -lssl -lcrypto

[링크 : https://stackoverflow.com/questions/12917731/linking-issues-using-openssl-in-ubuntu]


+

nc 테스트

접속시 connection from이 뜨고

sadf를 입력하니 error가 나오며 접속이 종료된다.

$ ./srv
Enter PEM pass phrase:
Connection from 100007f, port 96c5
140278452101568:error:1408F10B:SSL routines:ssl3_get_record:wrong version number:../ssl/record/ssl3_record.c:332:


$ nc localhost 1111

sadf

'Linux API > network' 카테고리의 다른 글

AF_PACKET로 link layer 열기  (0) 2022.06.09
linux tcp server listen accept connect  (0) 2022.05.11
TCP timeout  (0) 2020.09.29
UDS (Unix Domain Socket)  (0) 2020.09.01
raw socker과 promiscous mode  (0) 2019.07.03
Posted by 구차니
Linux API/linux2022. 2. 11. 11:06

tmpfs에 touch로 파일을 생성/삭제하면서 테스트 해보니

마우스 이벤트에 묶여있어도 cpu 점유율 이 크게 오르지 않는걸 봐서는 부하가 크지 않은 듯.


if( access( fname, F_OK ) == 0 ) {
    // file exists
} else {
    // file doesn't exist
}

[링크 : https://stackoverflow.com/questions/230062/whats-the-best-way-to-check-if-a-file-exists-in-c]


#include <unistd.h>
int access(const char *pathname, int mode);

The mode specifies the accessibility check(s) to be performed, and is either the value F_OK, or a mask consisting of the bitwise OR of one or more of R_OK, W_OK, and X_OK. F_OK tests for the existence of the file. R_OK, W_OK, and X_OK test whether the file exists and grants read, write, and execute permissions, respectively.

[링크 : https://linux.die.net/man/2/access]


F_OK 파일 존재여부
R_OK 파일 read 퍼미션 여부
W_OK 파일 write 퍼미션 여부
X_OK 파일 execute 퍼미션 여부

'Linux API > linux' 카테고리의 다른 글

posix message queue  (0) 2022.09.21
zeroMQ  (0) 2022.09.20
select, poll, epoll  (0) 2021.11.02
Unhandled fault: external abort on non-linefetch  (0) 2021.05.25
Stopped (tty input)  (0) 2021.05.21
Posted by 구차니
Linux API/linux2021. 11. 2. 10:44

개략적으로 보면.. select나 poll이나 비슷하게 이벤트 발생시 누가 발생했는지 찾아서 처리해야 하고

epoll은 이벤트 발생시 발생목록을 전달하여, 누가 발생했는지 찾을 필요 없이 바로 처리하면 된다.

다만 select는 1024가 한번에 다룰수 있는 최대 fd 갯수고

poll은 숫자제한은 없지만 선형 탐색을 해야하고, 1500 넘으면 느려진다고 하고

epoll이 1500 보다 클 경우는 유리한 듯.


select / poll / epoll

[링크 : https://niklasjang.github.io/backend/select-poll-epoll/]

[링크 : https://applefarm.tistory.com/144]


select

while(1)
{
   fd_num = select(...);
   if(fd_num == -1) break;
   else if(fd_num == 0 ) continue;

   for(int fd =0; fd < fd_max + 1; ++fd)
   {
      if(FD_ISSET(fd, &cpy_reads))
      {
          // TODO
      }
   }

   close(server_socket);
   return 0;
}

[링크 : https://ozt88.tistory.com/21]


poll

       #include <poll.h>
       #include <fcntl.h>
       #include <sys/types.h>
       #include <stdio.h>
       #include <stdlib.h>
       #include <unistd.h>

       #define errExit(msg)    do { perror(msg); exit(EXIT_FAILURE); \
                               } while (0)

       int
       main(int argc, char *argv[])
       {
           int nfds, num_open_fds;
           struct pollfd *pfds;

           if (argc < 2) {
              fprintf(stderr, "Usage: %s file...\n", argv[0]);
              exit(EXIT_FAILURE);
           }

           num_open_fds = nfds = argc - 1;
           pfds = calloc(nfds, sizeof(struct pollfd));
           if (pfds == NULL)
               errExit("malloc");

           /* Open each file on command line, and add it 'pfds' array. */

           for (int j = 0; j < nfds; j++) {
               pfds[j].fd = open(argv[j + 1], O_RDONLY);
               if (pfds[j].fd == -1)
                   errExit("open");

               printf("Opened \"%s\" on fd %d\n", argv[j + 1], pfds[j].fd);

               pfds[j].events = POLLIN;
           }

           /* Keep calling poll() as long as at least one file descriptor is
              open. */

           while (num_open_fds > 0) {
               int ready;

               printf("About to poll()\n");
               ready = poll(pfds, nfds, -1);
               if (ready == -1)
                   errExit("poll");

               printf("Ready: %d\n", ready);

               /* Deal with array returned by poll(). */

               for (int j = 0; j < nfds; j++) {
                   char buf[10];

                   if (pfds[j].revents != 0) {
                       printf("  fd=%d; events: %s%s%s\n", pfds[j].fd,
                               (pfds[j].revents & POLLIN)  ? "POLLIN "  : "",
                               (pfds[j].revents & POLLHUP) ? "POLLHUP " : "",
                               (pfds[j].revents & POLLERR) ? "POLLERR " : "");

                       if (pfds[j].revents & POLLIN) {
                           ssize_t s = read(pfds[j].fd, buf, sizeof(buf));
                           if (s == -1)
                               errExit("read");
                           printf("    read %zd bytes: %.*s\n",
                                   s, (int) s, buf);
                       } else {                /* POLLERR | POLLHUP */
                           printf("    closing fd %d\n", pfds[j].fd);
                           if (close(pfds[j].fd) == -1)
                               errExit("close");
                           num_open_fds--;
                       }
                   }
               }
           }

           printf("All file descriptors closed; bye\n");
           exit(EXIT_SUCCESS);
       }

[링크 : https://man7.org/linux/man-pages/man2/poll.2.html]


epoll

int epoll_fd = epoll_create(EPOLL_SIZE);
struct epoll_event* events = malloc(sizeof(struct epoll_event)*EPOLL_SIZE);
struct epoll_event init_event;
init_event.events = EPOLLIN;
init_event.data.fd = server_socket;
epoll_ctl(epoll_fd, EPOLL_CTL_ADD, server_socket, &init_event);
while(TRUE)
{
   int event_count = epoll_wait(epoll_fd, events, EPOLL_SIZE, -1);
   if( event_count = -1 ) break;
   for( int i = 0 ; i < event_count; ++i )
   {
      if(events[i].data.fd == server_socket) //서버 소켓에 이벤트
      { //accept 처리 ... init_event.events = EPOLLIN;
         init_event.data.fd = new_client_socket;
         epoll_ctl(epoll_fd, EPOLL_CTL_ADD, new_client_socket, &init_event);
      }
      else //이벤트가 도착한 소켓들
      {
            //read, write, closesocket처리
      }
   }
}

closesocket(server_socket);
close(epoll_fd);
return 0;

[링크 : https://ozt88.tistory.com/21]


+

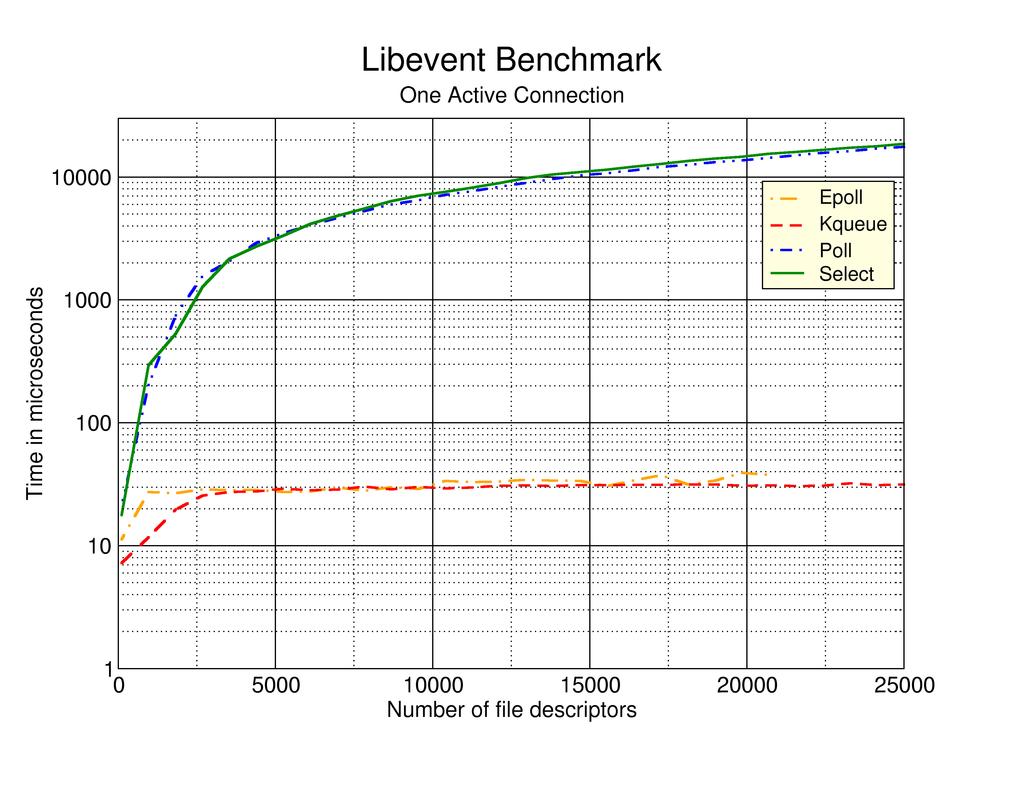
오래된 글이지만 벤치마크 결과 poll/select는 거의 동일한 성능이고

fd 갯수가 늘어갈수록 느려지지만, epoll이나 kqueue의 경우 일정 상한 이상으로는 성능이 유지되는 경향을 보인다.

[링크 : https://monkey.org/~provos/libevent/libevent-benchmark.jpg]

[링크 : https://kldp.org/node/46542]


일반적으로 소켓수가 1500이하일때는 퍼모먼스 차이는 거의 없는것으로 알고 있습니다.

select poll epoll 의 성능차이는 5000 이상부터 급격히 달라집니다.

[링크 : http://foroum.gpgstudy.com/forum/viewtopic.php?t=12610]

'Linux API > linux' 카테고리의 다른 글

zeroMQ  (0) 2022.09.20
파일 존재유무 확인하기  (0) 2022.02.11
Unhandled fault: external abort on non-linefetch  (0) 2021.05.25
Stopped (tty input)  (0) 2021.05.21
linux gpio interrupt poll?  (0) 2021.05.04
Posted by 구차니
Linux API/linux2021. 5. 25. 15:00

mmap()으로 특정 메모리 영역을 접근하는데

이상한 순서로 에러 메시지가 뒤죽박죽 되어 나와서 겨우겨우 복구(?) 해봤더니 더 멘붕오는 듯한 용어만 잔뜩 -_-

Unhandled fault: external abort on non-linefetch (0x1818) at 0x70000000
pgd = cdbbc000
Error: [70000000] *pgd=0dbc3831, *pte=70000743, *ppte=70000c33


ppte는 약어를 못 찾음 (느낌은 pte에 대한 pointer 아닐까 싶긴 하지만..)

PGD : Page Global Directory
PTE : Page Table Entries

[링크 : https://www.kernel.org/doc/gorman/html/understand/understand006.html]


(0x1818) 음.. 딱 적절한 나의 마음을 나타내는 값은 ifsr 레지스터 라는데

The values in parenthesis are the ifsr (instruction fault status) register

[링크 : https://stackoverflow.com/questions/15889483/what-do-these-kernel-panic-errors-mean]


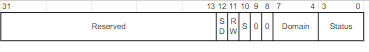
레지스터값의 의미를 요약하면 다음과 같은데

AXI Slave error로 인해서 abort가 발생,
write access가 abort를 발생
D1 domain?
precise external abort, nontranslation

도대체 무슨 말이야!!!


SD
Indicates whether an AXI Decode or Slave error caused an abort. This bit is only valid for external aborts. For all other aborts this bit Should Be Zero:
0 = AXI Decode error caused the abort, reset value
1 = AXI Slave error caused the abort.

RW
Indicates whether a read or write access caused an abort:
0 = read access caused the abort, reset value
1 = write access caused the abort.

Domain
Indicates which one of the 16 domains, D15-D0, is accessed when a data fault occurs. This field takes values 0-15.

Status
Indicates the type of exception generated. To determine the data fault, bits [12] and [10] must be used in conjunction with bits [3:0]. The following encodings are in priority order, 1 is the highest:

0b000001 alignment fault
0b000100 instruction cache maintenance fault
0bx01100 L1 translation, precise external abort
0bx01110 L2 translation, precise external abort
0b011100 L1 translation precise parity error
0b011110 L2 translation precise parity error
0b000101 translation fault, section
0b000111 translation fault, page
0b000011 access flag fault, section
0b000110 access flag fault, page
0b001001 domain fault, section
0b001011 domain fault, page
0b001101 permission fault, section
0b001111 permission fault, page
0bx01000 precise external abort, nontranslation
0bx10110 imprecise external abort
0b011000 imprecise error, parity or ECC
0b000010 debug event.

[링크 : https://developer.arm.com/documentation/.../c5--data-fault-status-register]


[링크 : https://github.com/brgl/busybox/blob/master/miscutils/devmem.c]

'Linux API > linux' 카테고리의 다른 글

파일 존재유무 확인하기  (0) 2022.02.11
select, poll, epoll  (0) 2021.11.02
Stopped (tty input)  (0) 2021.05.21
linux gpio interrupt poll?  (0) 2021.05.04
Floating point exception  (0) 2021.04.05
Posted by 구차니
Linux API/linux2021. 5. 21. 17:33

stdin을 통해 입력을 받아 작동하는 프로그램을 쉘에서 실행하고 백드라운드로 돌리니 멈춘다?!

bg
[1] /test
#
[1]+  Stopped (tty input)        /test


[링크 : https://topic.alibabacloud.com/...-stopped-tty-input_1_16_30150438.html]

[링크 : https://unix.stackexchange.com/questions/294471/backgrounded-job-keeps-stopping]


아무튼 SIGTTIN이 들어와서 그렇다고 하는데

간단하게는.. 해당 시그널을 무시하면 되는거고..

다른 방법은 좀 더 고민해 봐야 할 듯 -_-


void
init_shell ()
{

  /* See if we are running interactively.  */
  shell_terminal = STDIN_FILENO;
  shell_is_interactive = isatty (shell_terminal);

  if (shell_is_interactive)
    {
      /* Loop until we are in the foreground.  */
      while (tcgetpgrp (shell_terminal) != (shell_pgid = getpgrp ()))
        kill (- shell_pgid, SIGTTIN);

      /* Ignore interactive and job-control signals.  */
      signal (SIGINT, SIG_IGN);
      signal (SIGQUIT, SIG_IGN);
      signal (SIGTSTP, SIG_IGN);
      signal (SIGTTIN, SIG_IGN);
      signal (SIGTTOU, SIG_IGN);
      signal (SIGCHLD, SIG_IGN);

      /* Put ourselves in our own process group.  */
      shell_pgid = getpid ();
      if (setpgid (shell_pgid, shell_pgid) < 0)
        {
          perror ("Couldn't put the shell in its own process group");
          exit (1);
        }

      /* Grab control of the terminal.  */
      tcsetpgrp (shell_terminal, shell_pgid);

      /* Save default terminal attributes for shell.  */
      tcgetattr (shell_terminal, &shell_tmodes);
    }
}

[링크 : https://www.gnu.org/software/libc/manual/html_node/Initializing-the-Shell.html]


Macro: int SIGTTINA process cannot read from the user’s terminal while it is running as a background job. When any process in a background job tries to read from the terminal, all of the processes in the job are sent a SIGTTIN signal. The default action for this signal is to stop the process. For more information about how this interacts with the terminal driver, see Access to the Terminal.

[링크 : https://www.gnu.org/software/libc/manual/html_node/Job-Control-Signals.html]

'Linux API > linux' 카테고리의 다른 글

select, poll, epoll  (0) 2021.11.02
Unhandled fault: external abort on non-linefetch  (0) 2021.05.25
linux gpio interrupt poll?  (0) 2021.05.04
Floating point exception  (0) 2021.04.05
실행파일 not fount, FATAL: kernel too old  (0) 2021.04.05
Posted by 구차니